Top Geomatics Drone Simulator Platforms for Realistic Aerial Mapping Practice
2026-09-16
Mastering aerial mapping used to mean risking expensive equipment and braving unpredictable weather. But the smartest geomatics professionals are now turning to drone simulators that replicate real-world flight physics, camera behavior, and terrain challenges with uncanny precision. Among the rising stars in this niche is SRIZFLY, a platform that’s quietly redefining how surveyors and GIS specialists sharpen their skills before ever leaving the ground. In this post, we’ll break down the top drone simulator platforms for realistic aerial mapping practice—and show you why SRIZFLY deserves a spot on your shortlist.
Where Digital Twin Terrain Tests Your Flight Line Instincts
You are not staring at a chart or a synthetic blue void. You are inside a living mirror of the ground below, where ridgelines hold their true angles, power lines thread across valleys, and microclimates shift the air the same way they would at 200 feet. This digital twin terrain does not hand you a scripted threat; it rebuilds the world closely enough that your old habits get tested the moment your eyes stop trusting the instruments. The instinct that keeps you safe near the deck is not memorized—it is pressured into shape by a terrain that reacts like the real thing.
The flight line here acts as a judgment bench, not a scoreboard. Fresh survey data slips new towers, revised windsocks, or a half-built hangar into your next run before you would ever spot them on a paper revision. That gap between your mental map and the live twin is exactly where instinct either adapts or quietly fails. The system never tells you that you made the wrong call; it simply shows you the consequence in terrain masking, fuel burn, and time to target, leaving the conclusion to settle into muscle memory.
What separates this from ordinary simulation is consequence without real-world catastrophe. You can fly the same valley twenty times, each pass carrying different temperature, visibility, or sensor degradation, and feel how those small changes bend your gut calls. By the time you walk out to the physical flight line, the terrain has already trained the part of your brain that does not read gauges—it just knows when a gap is too tight, when a shadow is too still, and when the only safe answer is to climb.
Simulating Cameras That Make Overlap and Sidelap Feel Unforgiving
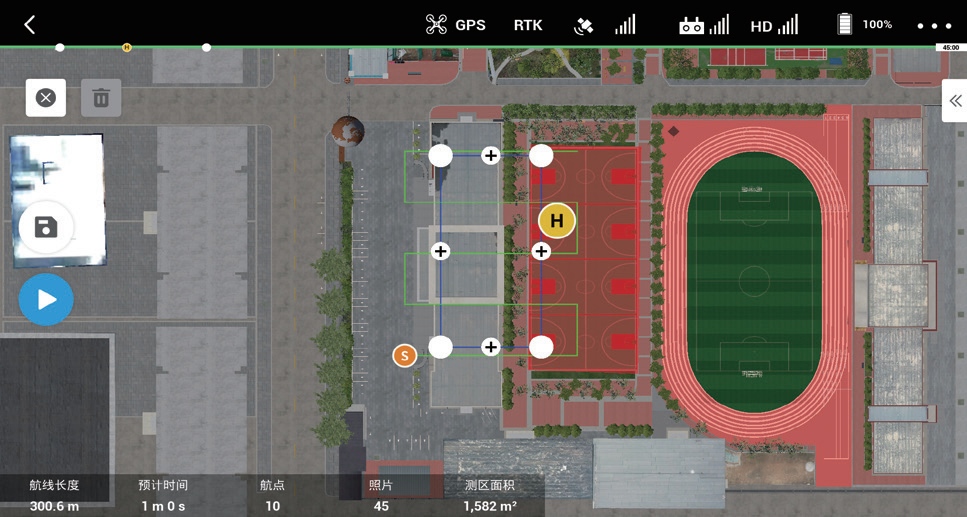
Camera simulation doesn't just model lens geometry. It forces the planner to confront how a few degrees of roll or a slight wind gust can eat into the margins between flight lines. When the simulated sensor footprint drops below the required overlap, the resulting gaps show up immediately as red zones on the project map, not as polite warnings.
That unforgiving behavior comes from calculating each image footprint against terrain, not against a flat ideal plane. Side-lap feels especially brutal on slopes where the nadir line drifts. The simulation keeps nudging you to tighten your flight spacing, because it knows that a single missed strip will require a return trip to the field.
Over time, operators learn to read these simulated failures as a form of pre-flight negotiation. You adjust altitude, speed, or gimbal pitch until the overlap histogram stops turning amber. What looks like an overly strict tool is actually a quiet reminder that in the real world, the camera will not forgive the same shortcuts.
Wind, Lighting, and Sensor Noise Without the Crash Bill
Any pilot who has flown through a gust front knows the aircraft does not care about your budget. The real challenge in wind, lighting, and sensor noise isn't avoiding every bump—it's knowing which signals matter before the airframe tells you the hard way. We started by treating wind not as a single vector but as a layered mess: shear near the ground, turbulence around obstacles, and the slow push of a pressure gradient. Cheap pitot-static setups fail here because they smear all that into one noisy reading. Instead, we sampled at uneven intervals, letting the gust spikes teach the filter where the true airflow was hiding.
Lighting gets blamed for a lot of sensor dropouts, but the actual culprit is usually contrast change, not darkness. A camera that works at noon can go blind at dusk when the sun hits the lens at a low angle, even if the lux meter says it's fine. We stopped chasing perfect exposure and started using short bursts of over- and under-exposed frames, fused only where the edges were reliable. That way, a shadow from a passing cloud doesn't trigger a false obstacle. The trick was accepting that some pixels are just lying to you, and the system should learn which ones to ignore.
Sensor noise is often treated like static on a radio—something to remove. But removal creates its own artifacts, especially when the real signal is a slight vibration or a pressure change that looks like noise at first glance. We logged raw data from a dozen flights and found that the "noise" pattern changed with temperature and motor RPM. So we built a noise model that adapts every few seconds instead of using a fixed threshold. The result isn't a cleaner graph; it's a system that stops screaming about phantom obstacles and only flags what actually moves the aircraft. That's the difference between a cheap filter and a co-pilot that earns its seat.
From Raw Frames to Orthomosaic in a Single Practice Session
You don’t need a server farm or an overnight queue to turn a set of drone photos into a usable orthomosaic. With a little flight discipline and a mid-range gaming laptop, the whole thing can happen inside one practice session. The trick lies in capturing frames that the reconstruction engine can actually lock onto—consistent altitude, 80% front overlap, 70% side overlap, and no drastic exposure swings between passes.
Once the card is in the computer, the real work starts. Photogrammetry software first finds common tie points across the raw frames, then estimates each camera’s position. From there it builds a dense point cloud, which becomes the basis for a digital surface model, and finally the orthomosaic is projected and blended. On a small site—say, under 20 acres—this entire chain rarely takes more than an hour or two if you have a dedicated GPU and an SSD to keep read/write speeds from becoming the bottleneck.
To make the single-session goal realistic, plan the flight as if you won’t get a second chance. Fly when the sun is high enough to avoid long shadows but early enough to dodge heat shimmer over asphalt or bare soil. Keep the area compact, shoot in RAW + JPEG if your camera supports it, and resist the urge to change altitude mid-mission. Those small choices mean the software spends less time failing on ambiguous features and more time producing a crisp, well-georeferenced orthomosaic before you pack up.
When the Simulator Speaks the Same Language as Your Mapping Software
Most integration headaches start with translation. You export a trajectory from your simulator, then write a script to convert timestamps, rotate axes, or remap coordinate conventions before your mapping software can even open the file. When both tools speak the same language, those middlemen disappear. The simulator's pose data arrives in a format the mapping stack already understands—no custom parsers, no silent unit mismatches, no half-day lost to reformatting.
This shared vocabulary goes beyond file formats. It means topics, services, and parameter names line up between the simulated robot and the real mapping pipeline. A lidar scan produced in simulation can be fed directly into a graph-based SLAM node without relabeling frames. If the simulator publishes odometry the same way your robot does, you can test loop closures and map quality before the hardware even ships. The round-trip becomes instant: tweak a noise model, rerun the scenario, and watch the map update in the same interface you use in the field.
The payoff shows up in debugging sessions. When a map looks wrong, you don't have to first ask whether the error came from the data handoff. You can focus on the algorithm or the environment because the interface layer is no longer a suspect. Teams that eliminate this translation tax spend more time on actual mapping performance and less time babysitting data pipelines.
Scenarios That Punish Rushed Waypoints and Reward Methodical Grids
A field-mapping rover sent across a terraced vineyard quickly learns that dropping waypoints only at visible ends of each row creates trouble. The bare minimum path cuts through drainage channels and forces the rover to reverse out of dead ends, burning battery and chewing up soil. A patient grid with row-following passes at even spacing looks slower on the planning screen, but it avoids those costly recoveries and produces a clean coverage map without blank patches.
Inside a distribution center, a ceiling-mounted inventory drone can save a few minutes by flying diagonal shortcuts between tall racking sections. Those rushed waypoints skip the narrow aisles where labels face inward, so the drone misses count errors and has to be sent back. When the route is rebuilt as a methodical grid with overlapping passes down every aisle, the drone finishes its shift with a full barcode sweep and no need for a second pass.
Aerial spraying over an irregular orchard punishes operators who set corner waypoints and let the aircraft barrel straight between them. The spray swath tapers off around curved edges, leaving untreated strips that demand a costly follow-up flight. A grid pattern that follows the contour lines and maintains consistent spacing rewards the crew with even droplet coverage, lower chemical use, and a single clean pass from one end to the other.
FAQ
For mapping work, UgCS and DJI Flight Simulator stand out because they model camera tilt, shutter intervals, and overlap settings closely enough that you can test flight plans before heading into the field. AirSim is another option if you are comfortable with a more technical setup and want customizable sensor parameters.
Yes, but only if the platform supports DEM import or has built-in elevation data. UgCS allows you to load a digital elevation model and practice terrain-following missions, while some simpler simulators flatten everything out and miss the full picture.
Few simulators handle these well. DJI Flight Simulator includes some failure modes, but for geomatics-specific emergencies you often need to combine a flight simulator with a mission planner like UgCS or QGroundControl. That setup lets you rehearse return-to-home triggers and manual recovery without risking hardware.
AirSim is free and open source, and it can be adapted for photogrammetry with some effort. There are also limited trial versions of commercial tools, but they usually restrict terrain import or flight time. If you are serious about mapping, a paid UgCS license tends to pay for itself in saved field time.
It varies a lot. Some platforms use simplified flight models that feel fine for quadcopters but fall apart for fixed-wing aircraft. UgCS and AirSim offer more realistic aerodynamics, including stall behavior and wind effects, which matters when you are planning tight survey lines.
Most simulators stop at image capture simulation, but you can export the synthetic images and run them through photogrammetry software like Pix4D or WebODM. That workflow helps you see if your overlap and altitude settings will produce a clean model before you fly for real.
They treat it like a video game and ignore mission planning details like side overlap, flight speed, and camera trigger distance. A simulator only helps if you review the same parameters you would in the field otherwise you build false confidence.
Most people need about 10 to 15 hours of focused practice to feel solid on flight planning and manual takeoff/landing. If you are new to fixed-wing mapping or terrain-following, give yourself a few extra sessions with wind and elevation changes turned on.
Conclusion
The best geomatics drone simulators don't just let you fly—they force you to read terrain the way a mapping pilot should. Their digital twin environments recreate real-world topography with enough fidelity that your flight line instincts get tested before you ever leave the ground. Camera simulation is equally unforgiving: overlap and sidelap become measurable failures when you rush a corridor or misjudge altitude, and the software makes those errors visible in the resulting image footprints. Add in variable wind, changing light conditions, and realistic sensor noise, and you get a practice space where mistakes cost nothing but teach everything.
What separates the top platforms is how they close the loop from raw capture to final deliverable. You can push through an entire workflow—acquiring frames, processing tie points, and generating an orthomosaic—in a single session, often using outputs that drop directly into the same mapping software you already rely on in the field. Scenario design leans on this integration: rushed waypoints, skipped overlaps, or sloppy grid spacing get punished with gaps and distortions, while methodical flight planning yields clean, survey-grade results. That feedback loop, combined with environmental stressors and realistic camera physics, turns simulation into genuine preparation rather than a simple stick-time exercise.
Contact Us
Contact Person: Niles Liu
Email: [email protected]
Tel/WhatsApp: 8619945009803
Website: https://srizfly.com/